I have just wrapped up a fantastic week in Boston delivering robotics seminars at MIT and Northeastern University on the future of robotics and physical AI.
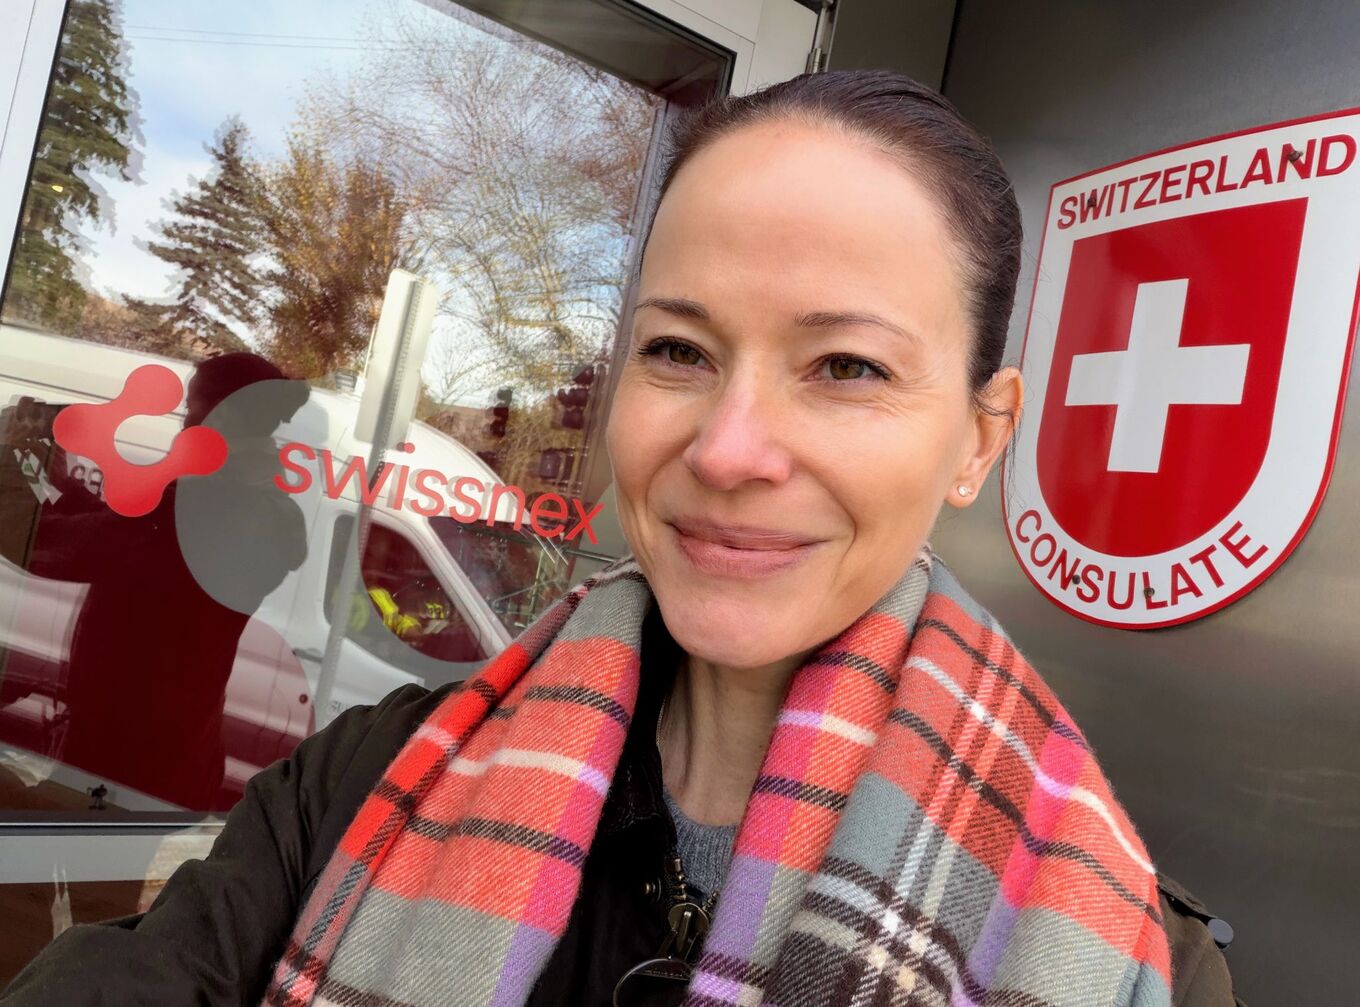
I am grateful to Seth Hutchinson for hosting me at Northeastern, and to Gioele Zardini for the warm welcome at MIT. It was wonderful to reconnect with old friends and colleagues, and to meet so many new researchers across both campuses to discuss the frontiers of robotics and multi-agent systems. I also had the pleasure of connecting back with my roots by visiting the office of Swissnex in Boston and New York for a conversation about the thriving ecosystem of Swiss robotics startups.
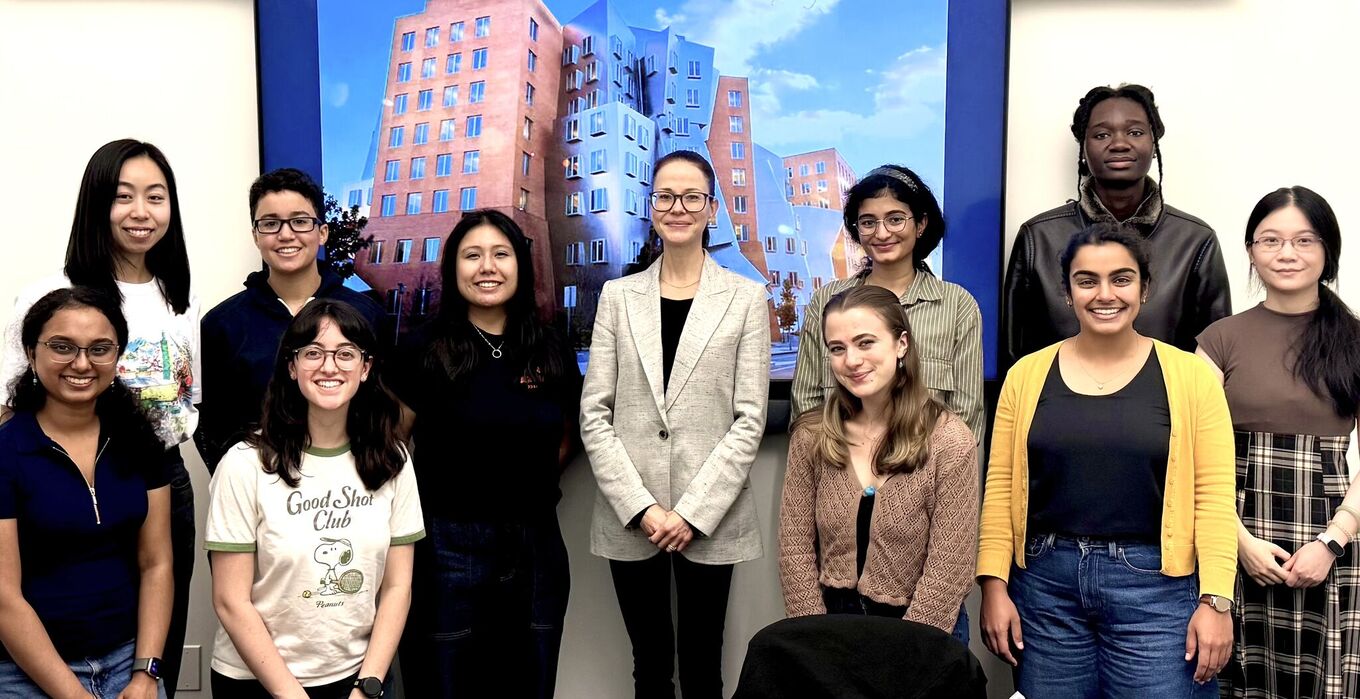
A special highlight of the trip was sitting down with the MIT Graduate Women in Robotics group (a special thanks to Jasmine Jerry Aloor) - it is always an absolute privilege to connect with the next generation of leaders in our field. We had a wonderful, candid discussion spanning the latest in robotics research to navigating career paths and leadership as a woman in academia. Those conversations felt especially real and relevant given that I was doing this entire trip with my two young kids in tow…
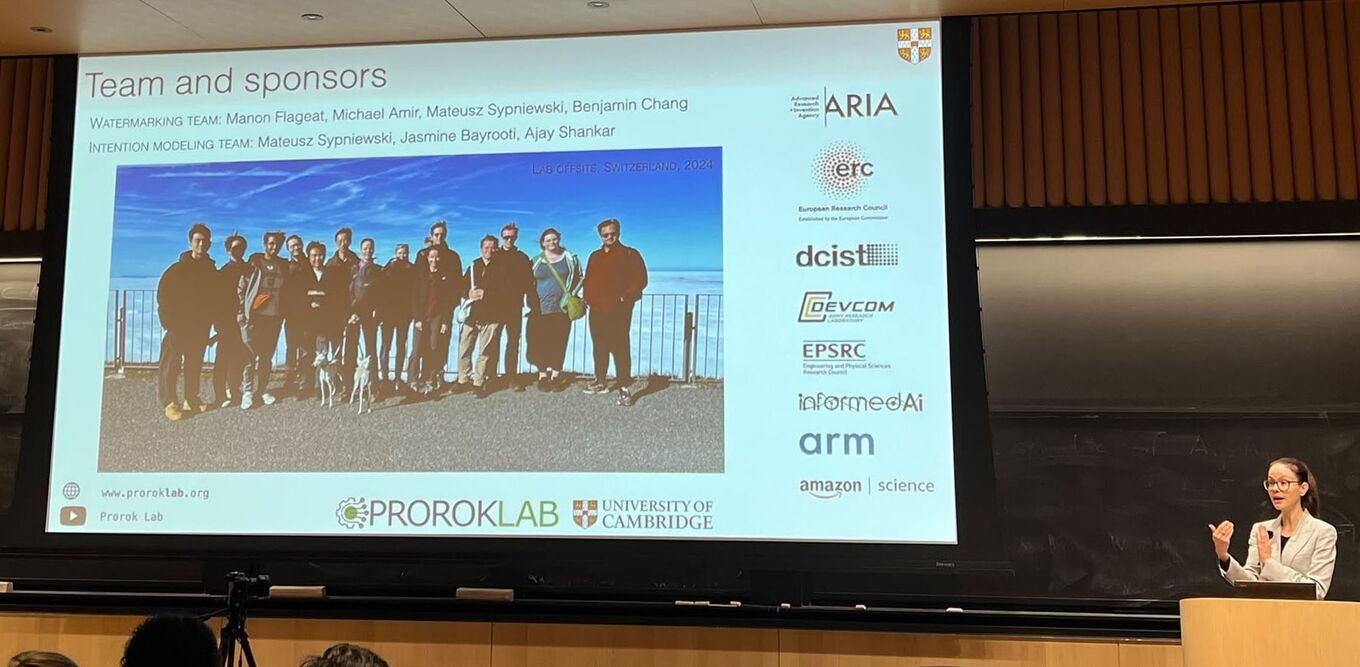
During my seminars, “Readable Robots: Authenticating and Modeling Behavior in Physical AI,” we dug into the critical bottleneck of trust and accountability as autonomous swarms enter public environments. I shared our recent work on closing the “Physical Observation Gap” by transforming physical motion itself into a communication channel for fingerprinting, bypassing traditional wireless links entirely. We also explored the flip side of the equation: how agents can dynamically learn and predict the hidden behaviors of their peers to achieve robust decision-making in complex spaces. Together, these building blocks are paving the way for an accountable ecosystem of physical AI, featuring both legible actors and adaptive perceivers.
Some of our papers I talked about are here (Prorok Lab):
- 📖 Remotely Detectable Robot Policy Watermarking
- 📖 Remotely Detectable Keyed Communication through Motion
- 📖 Generalized Intention Modeling in Multi-Agent Reinforcement Learning
Heading back to Cambridge feeling deeply inspired by the vibrant Boston robotics community…
#Robotics #PhysicalAI #MultiAgentSystems #MotionWatermarking #MIT #NortheasternUniversity #WomenInRobotics #WomenInSTEM #AutonomousRobot